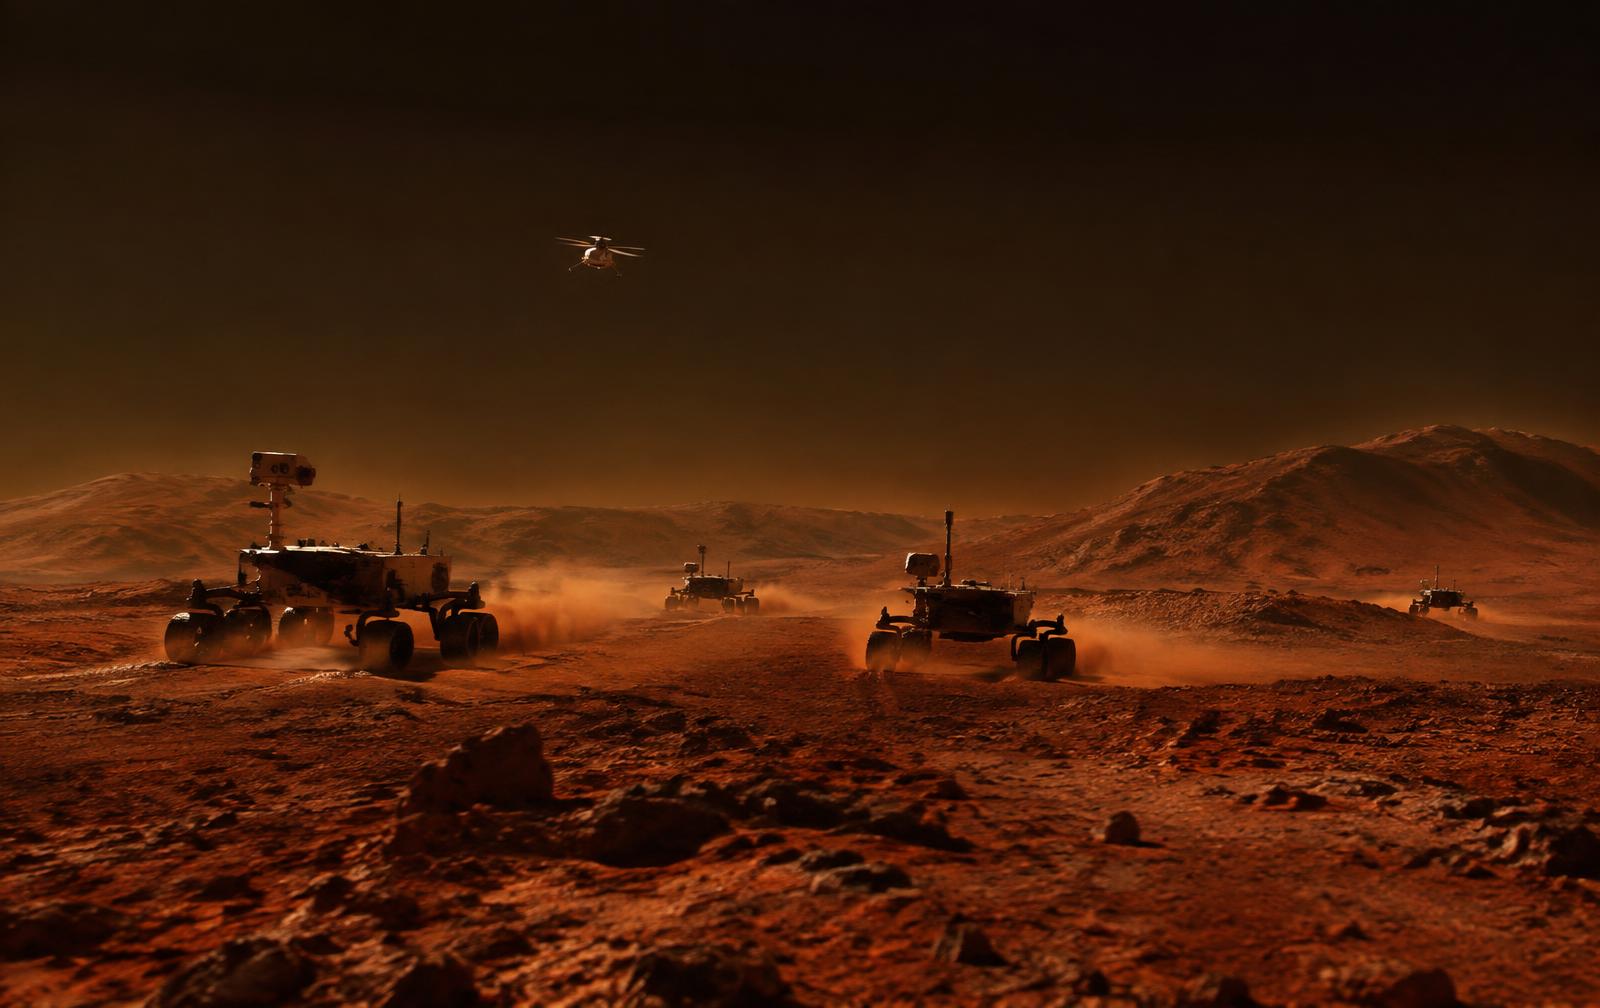
Fleet Guard turns a group of independent robots into a coordinated swarm. Instead of leaving every unit to negotiate paths on its own, the programme screens every planned trajectory, ranks genuine conflicts and proposes a concrete, energy-aware adjustment - within seconds, even under communications delay.
- Continuous all-versus-all screening of the full fleet plan
- Conflict probability with calibrated confidence
- Energy-aware path adjustments within seconds
- Secondary-conflict re-screening before every recommendation
On-swarm intelligence
The on-board AI screens planned paths as tasks are assigned, ranks which conflicts matter for the mission and shares only actionable adjustments with their geometry and timing. Path changes are validated by physics-based simulation before any recommendation reaches a unit's controller.
All-versus-all path screening
Every planned trajectory across the fleet is screened against every other, continuously. Geometric filters reduce the search space, and remaining candidates are evaluated with full uncertainty-based conflict probability, so alerts reflect real risk rather than raw proximity.
Path replanning
For each conflicting pair the engine searches for the smallest path adjustment that clears the encounter with margin, while respecting battery reserves, task deadlines and terrain constraints.
Secondary-conflict checking
Every candidate adjustment is re-screened against the full fleet plan before it is issued, so resolving one conflict never creates a new one elsewhere in the swarm.
Operator in the loop
Mission control keeps final authority over high-value manoeuvres. Recommendations arrive with the underlying geometry, conflict history and a plain-language rationale, so operators can approve, adjust or reject with full situational awareness despite the comms delay.