Mars orbit relay network
Orbiters, ground fleet and Earth combined into one resilient link chain.
Traffic is routed through a relay layer in Mars orbit before it ever needs a direct line to Earth. Surface robots talk to the nearest orbiter, orbiters store and forward data during Earth blackouts caused by planetary geometry, and multiple relay passes per sol keep the fleet from ever going fully dark. If one relay is out of view, traffic queues and moves through the next pass automatically.
- Store-and-forward relay through Mars orbit
- Multiple daily passes per surface asset
- No single relay is a point of failure
Delay-tolerant networking and protocol resilience
Communication designed for a 4–24 minute one-way light delay.
Standard internet-style protocols assume near-instant acknowledgement, which does not work across interplanetary distances. Our stack uses delay- and disruption-tolerant networking: data is bundled, prioritised and held at each hop until the next link opens, so nothing is lost when a connection drops mid-transfer. Command sequences are pre-validated on the ground and executed locally once received, instead of waiting for step-by-step confirmation.
- Bundle-based transport built for multi-minute delay
- Local execution of pre-validated command sequences
- No data loss across intermittent links
Optical and radio dual-band links
High-bandwidth laser links for bulk data, radio guarantees continuity.
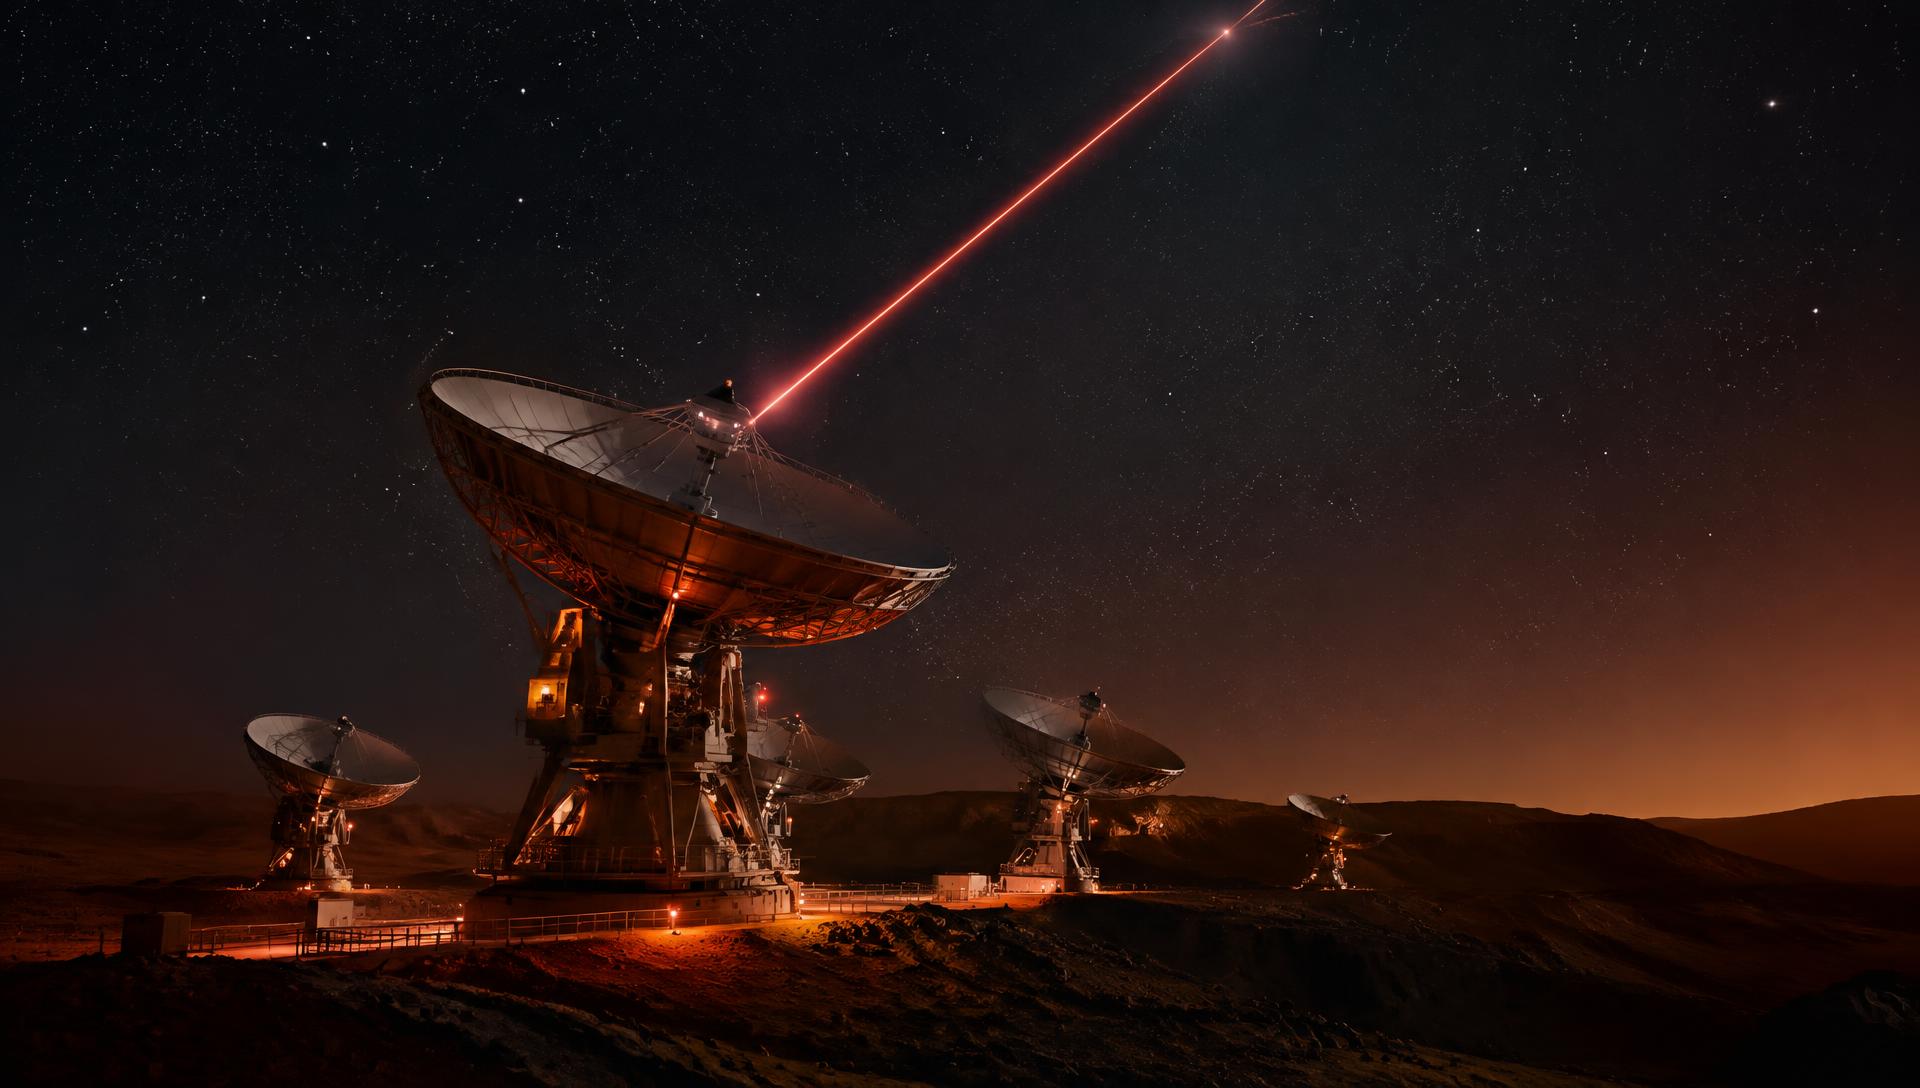
Optical links between surface assets, orbiters and Earth-facing terminals carry imagery, sample data and terrain scans at high bandwidth. Where dust, orientation or terminal constraints make optics impractical, encrypted radio channels take over automatically. The network decides continuously which path offers the best combination of latency, bandwidth and reliability under Martian dust and weather conditions.
- High-bandwidth optical links for imagery and terrain data
- Automatic fallback to radio bands
- Continuous path selection under dust and weather
AI link and fleet defence
The same terrain AI that guides a rover also protects its link.
Signal degradation, dust-storm attenuation, hardware faults and unusual command patterns are detected on board and answered automatically: antennas re-point, relay windows re-plan and affected units are isolated from the fleet network until diagnosed. Because navigation and connectivity share one platform, a terrain hazard and a link fault appear in the same fleet status view with the same time-to-act.
- Real-time detection of link degradation and faults
- Automatic antenna and relay-window reconfiguration
- Terrain and link status in one fleet view
Precision timing and localisation on the surface
A trusted clock and a trusted position, without satellite navigation.
Mars has no GPS equivalent, so timing and position are derived from orbiter beacons, terrain-relative navigation and cross-checks between fleet members. Every robot maintains a synchronised clock and a confidence-scored position estimate, which is essential for coordinated excavation, sample hand-off and safe operation near habitat construction sites.
- Orbiter-beacon and terrain-relative positioning
- Synchronised timing across the fleet
- Confidence-scored localisation for coordinated tasks
Terminals from rover to relay backbone
One network, from a single excavation unit to the Earth-facing backbone.
The same link protocol reaches a small scouting rover, a heavy excavation unit, a habitat assembly robot and the high-gain terminal that talks to Earth. Units authenticate themselves cryptographically, receive only the command classes they are cleared for, and can be quarantined from the fleet network within seconds if compromised or damaged.
- Scouting, excavation, assembly and relay terminals
- Cryptographic unit identity with instant quarantine
- Clearance-based access to command classes